The Very Hungry Caterpillar
A two-joint robot arm dressed as the caterpillar from Eric Carle’s picture book, driven by a joystick.
The arm
Keep scrolling to take it apart
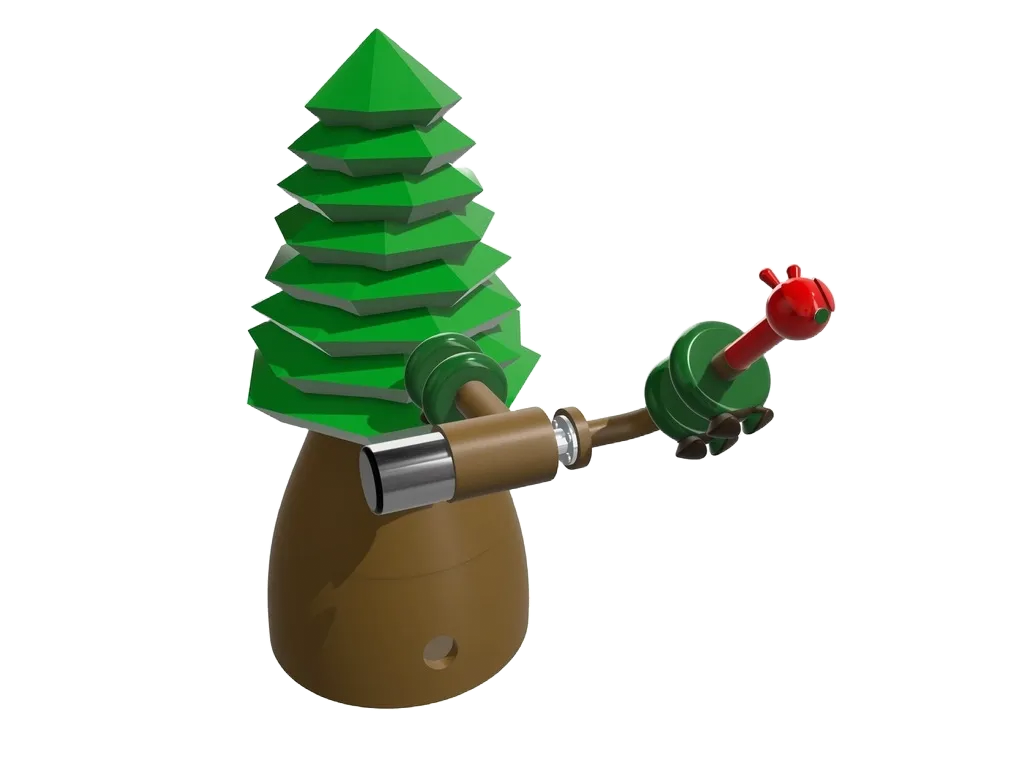
The tree spins. A wheel inside the canopy turns the whole arm.
The trunk is hollow and hides the electronics.
A floating motor hinge carries the arm.
The caterpillar’s head rides at the tip.
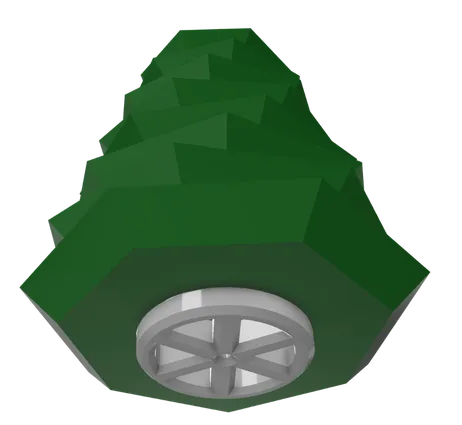
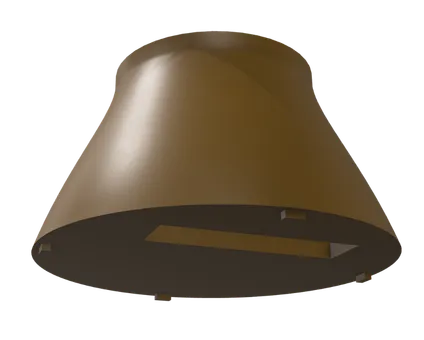
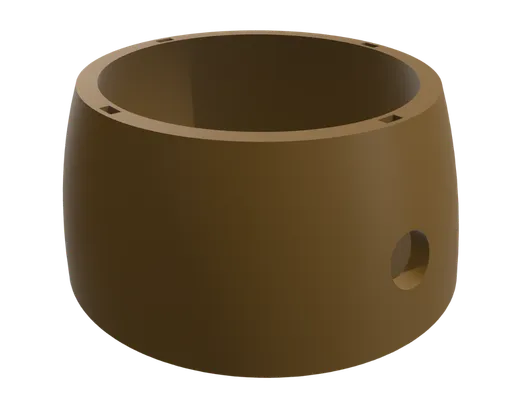
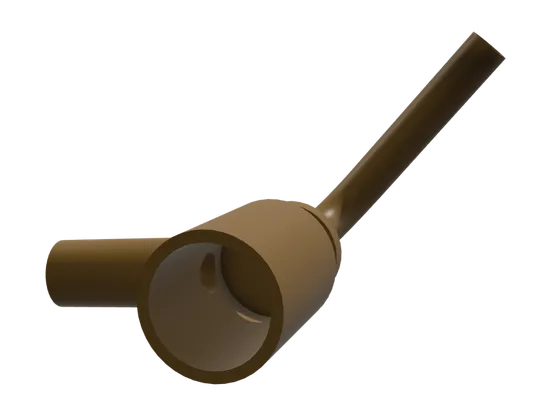
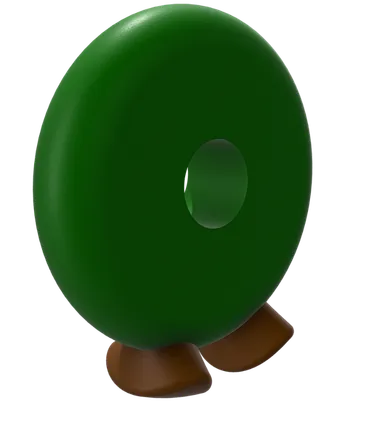
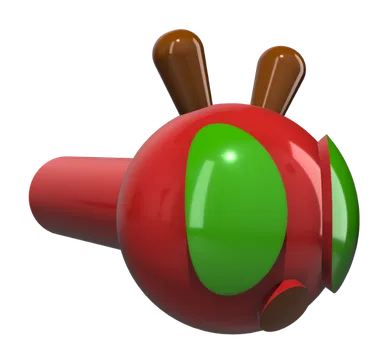
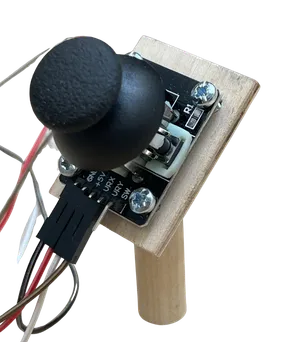
- 01Canopy and wheelIntegrated rotational mechanism. The wheel gives a controlled spinning motion.
- 02Housing, topCompact internal housing, with room to hide the components inside.
- 03Housing, baseModular assembly, for ease of use.
- 04Floating motor hingeThe joint the arm swings from.
- 05Body segmentPlayful form factor, for user engagement.
- 06HeadThe tip of the arm.
- 07Analog joystickIntuitive, proportional control over both motors’ direction.
- 08MDF base and wooden dowelsWhat it all stands on.
How it moves
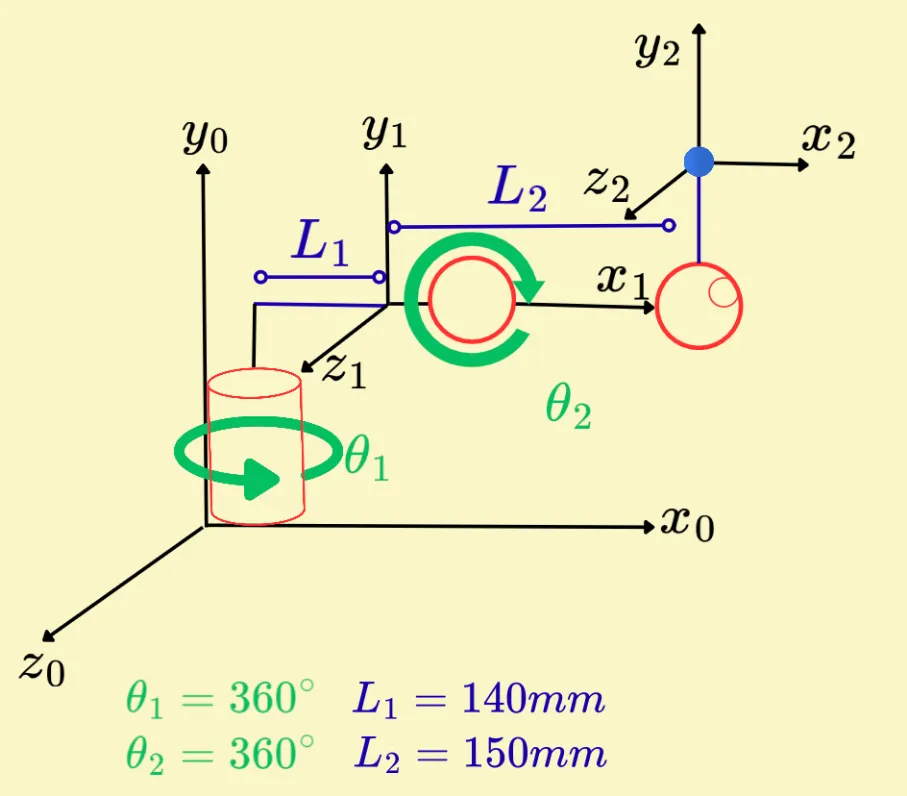
θ2 lifts the second link.
θ1 turns the whole arm about the trunk.
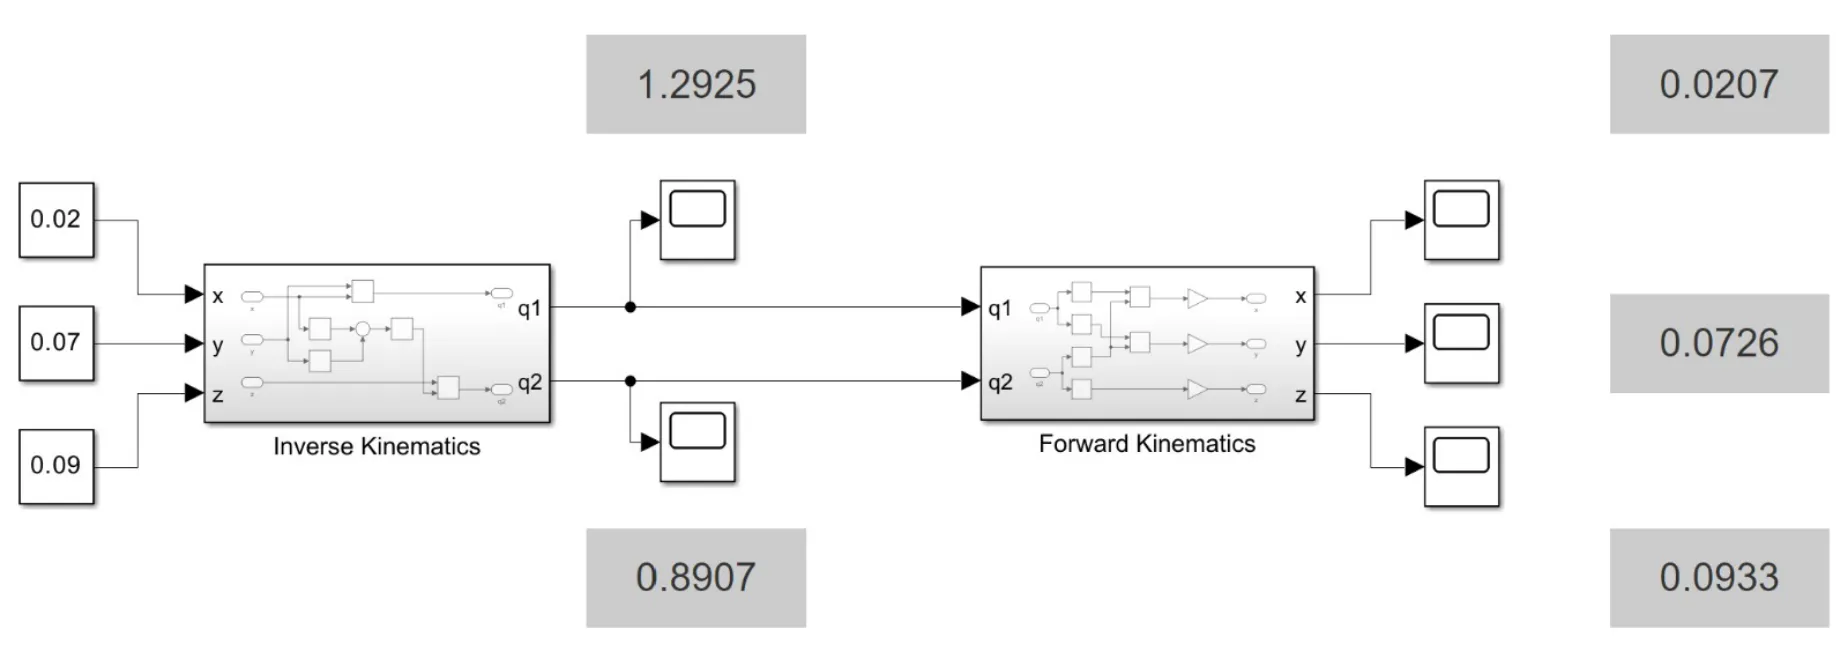
Forward kinematics
Inverse kinematics
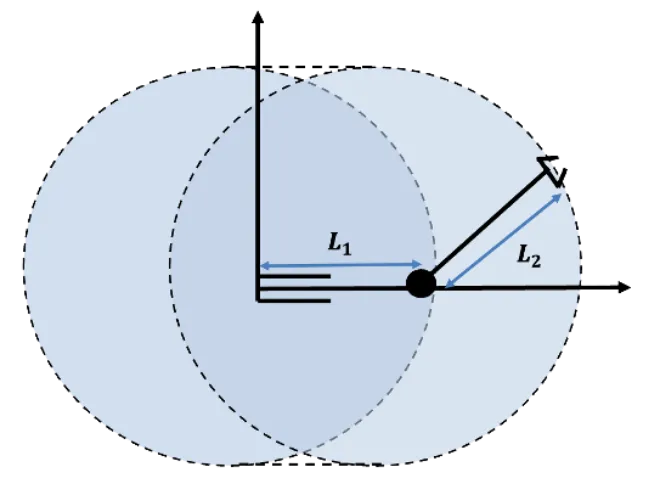
L1 140 mm · L2 150 mm · both joints 360°
Demo day
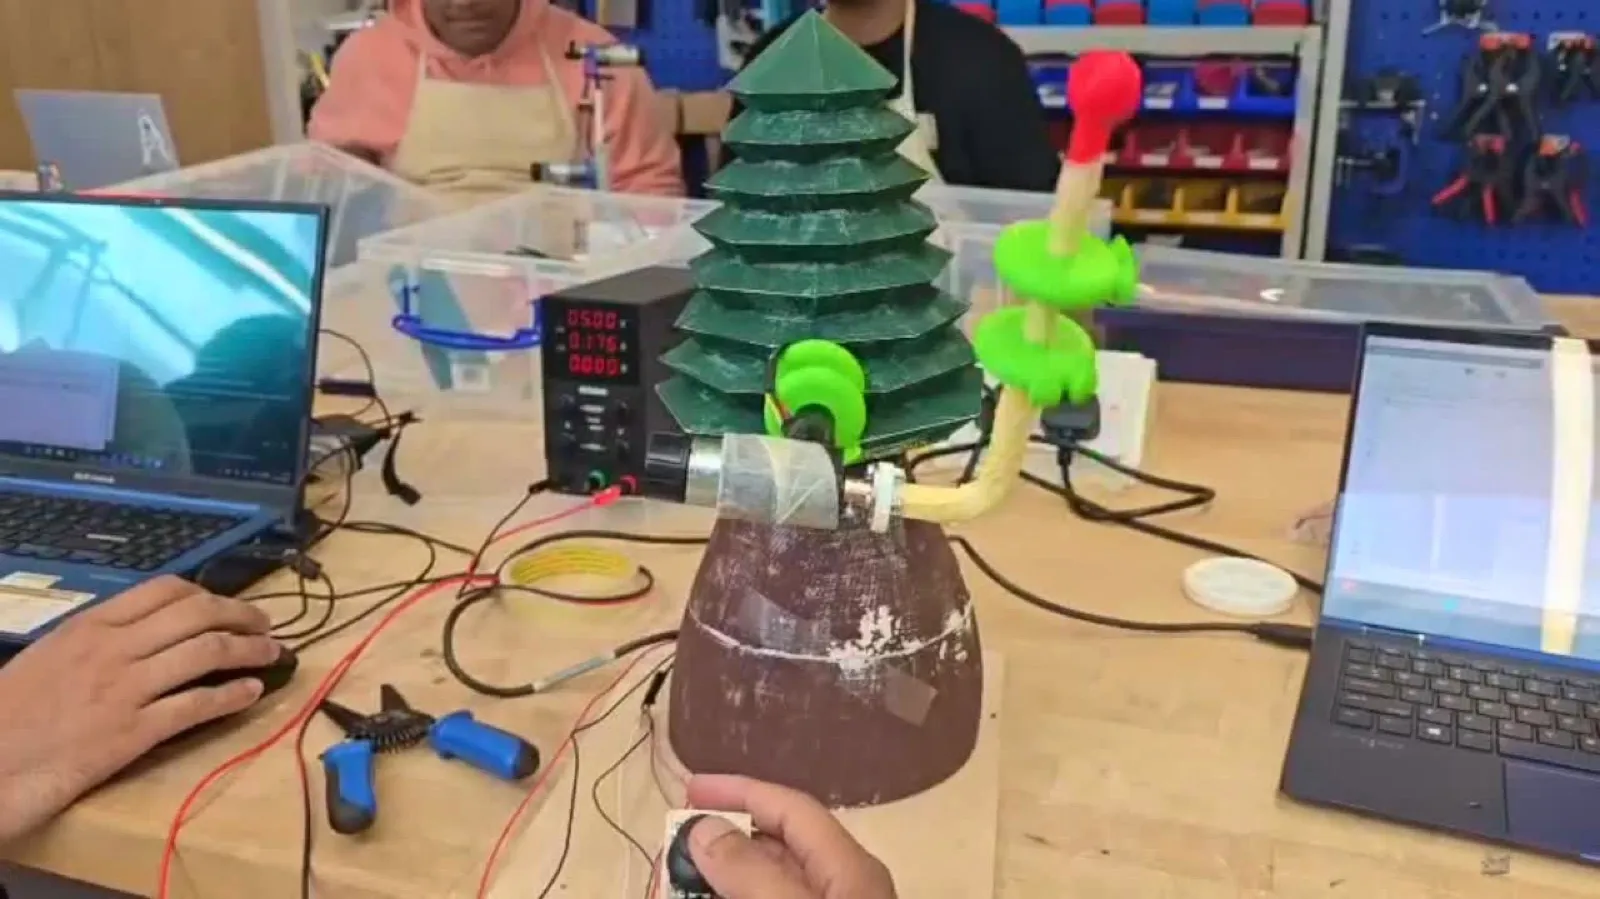
The bench supply. On demo day it was left at 12 V instead of 6 V.
Motor 2 accelerated fast enough to rip its own wires. The robot had been fully working throughout testing. It broke half an hour before we were due to present.
A voltage saturation block in the Simulink model would have prevented this entirely.